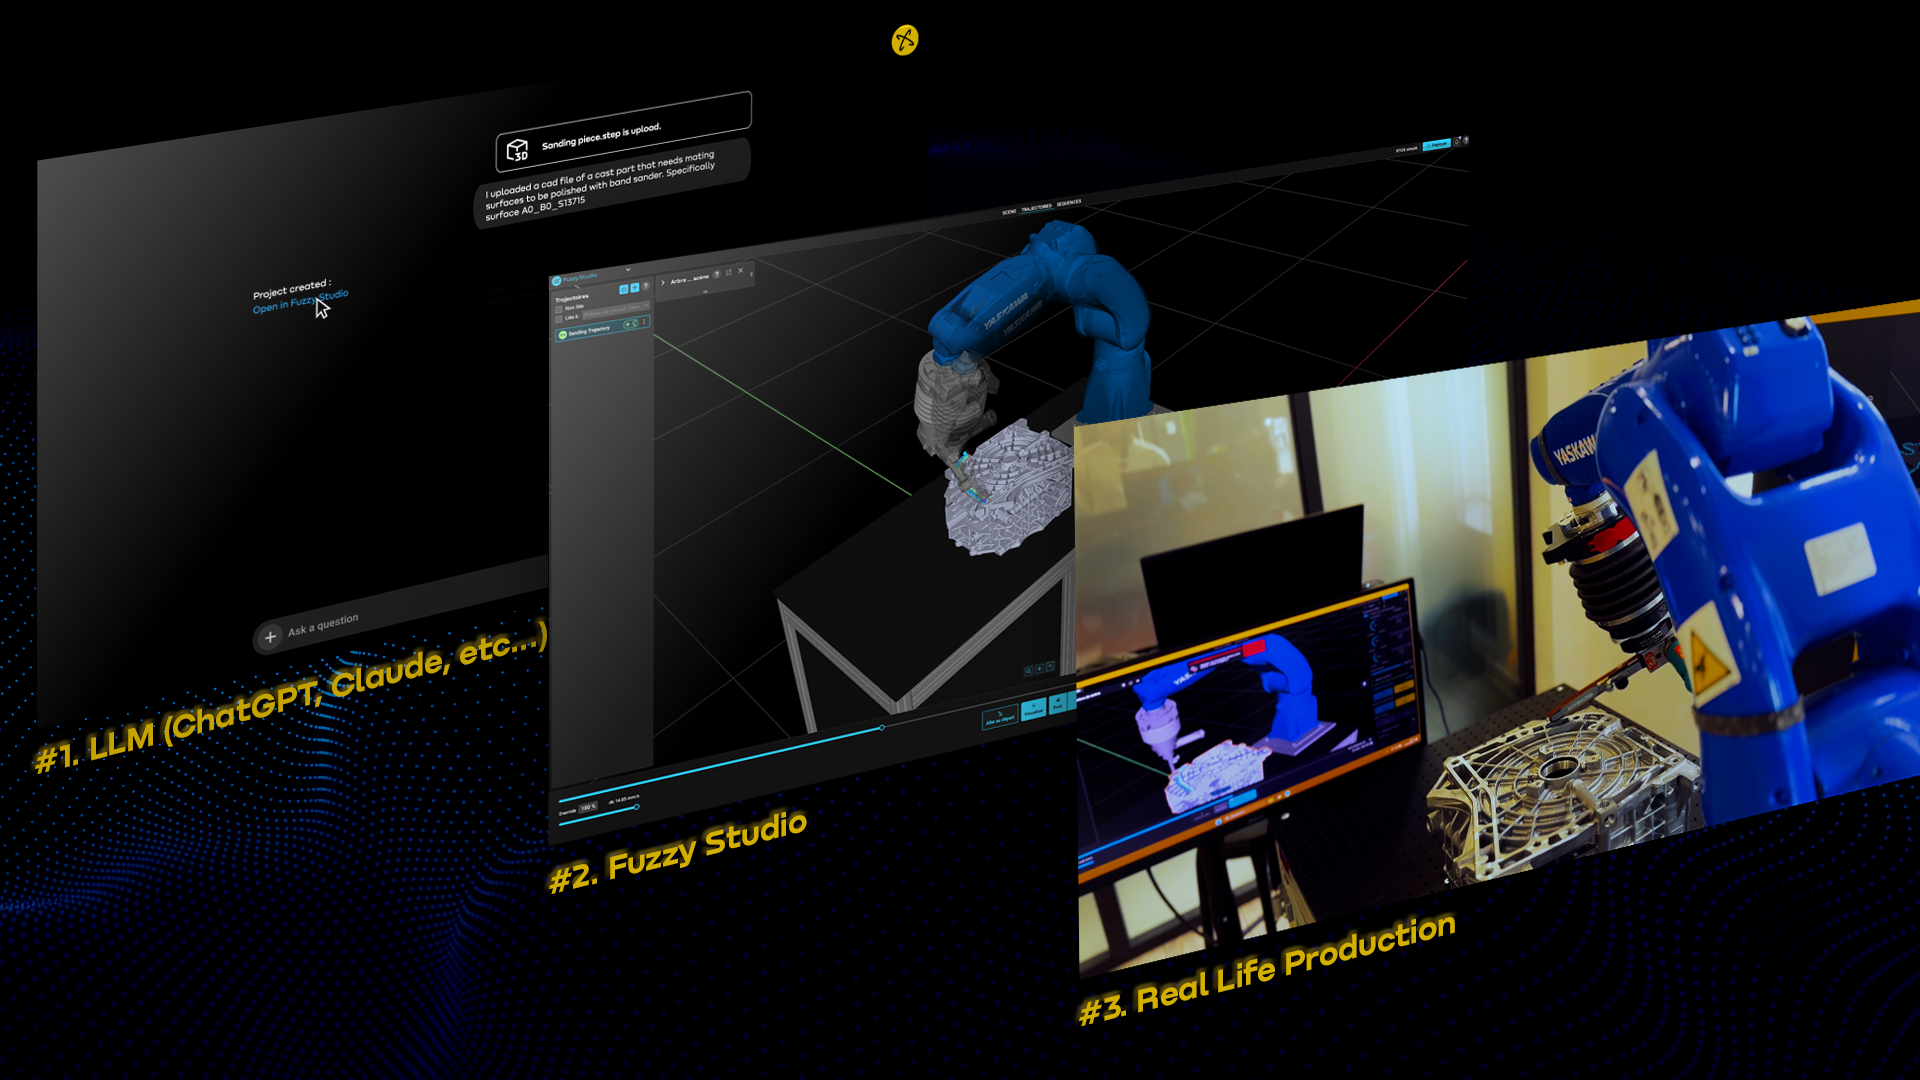
● Deterministic runtime execution through Fuzzy RTC
● Permissioned tools by risk level
Give AI agents a structured path from CAD and manufacturing intent to robot workcell creation, bounded motion,
factory integration, trajectory preview, and deterministic execution.
Large language models, VLA systems, and physical AI agents are becoming powerful enough to plan real-world tasks. But factories are not blank canvases. Industrial robots still require precise geometry, calibrated tools, valid trajectories, controller-specific execution, PLC coordination, safety equipment, operator procedures, and deployment discipline.
Fuzzy MCP Gateway bridges that gap. It lets AI systems propose and configure robot applications while Fuzzy Studio and Fuzzy RTC handle the industrial
robotics layer: CAD context, project structure, trajectory generation, motion constraints, driver state, preview, PLC-aware execution, and production runtime behavior.
With Fuzzy MCP Gateway, a developer can connect an AI agent to a Fuzzy robotics workflow and ask it to create
useful industrial robot applications.

Fuzzy MCP Gateway is designed around two existing Fuzzy Logic Robotics technologies:
The real-time control layer that abstracts industrial and collaborative robot brands behind a common runtime, trajectory system, state interface, execution API, and industrial integration layer.
The visual environment for CAD, workcell configuration, robot projects, tools, TCPs, trajectories, and application preview.
MCP gives AI clients a standard way to work with external systems. Fuzzy MCP Gateway turns robotics capabilities
into structured tools and resources.
● Task-level commands for CAD, cells, tools, trajectories, and sequences
● Approval gates available when the cell policy requires them
● Simulation and preview where appropriate
● Bounded streaming for real-time motion intent
● PLC, safety equipment, and operator workflow compatibility
● Permissioned tools by risk level
Bridge the gap between digital intelligence and physical execution. Deploy multi-modal AI agents capable of interacting with complex, unstructured factory environments safely.
Fine-tune and test your foundational models on production-grade robotics hardware. Validate spatial reasoning and task planning against real-world physical constraints.
Translate visual inputs and natural language tokens into safe, deterministic robot trajectories. Seamlessly integrate VLM pipelines with real-time industrial control.
Empower operators with intelligent shop-floor assistants. Enable real-time voice or text-driven task modification with full workspace safety enforcement.
Build next-generation no-code or low-code industrial frameworks. Expose complex kinematics solvers and path-planning modules through a simple, standardized API layer.
Automate feature extraction and toolpath generation directly from 3D assets. Let your AI agents interpret geometry constraints and generate ready-to-execute paths.
Optimize high-mix production cycles using adaptive reinforcement learning. Dynamically adjust process parameters for welding, grinding, or assembly on the fly.
Eliminate the Sim2Real gap. Safely transition policies trained in digital twins to real robot cells using FuzzyMCP’s deterministic safety boundaries.
No. Fuzzy MCP Gateway is intended to provide a structured AI interface to Fuzzy Studio and Fuzzy RTC. It does not replace certified safety systems, robot safety controllers, risk assessments, guarding, or operator procedures. Its role is to make AI-driven robotics compatible with those industrial realities, not to replace them.
Not by default. The intended architecture supports task-level commands such as creating workcells, generating trajectories, validating motion, and executing sequences. Where streaming motion intent is useful, Fuzzy RTC should enforce the robot-aware constraints before commands reach the robot.
Yes, that is the point. The goal is to support simulation, preview, bounded motion streaming, trajectory execution, and real robot deployment through Fuzzy RTC, while fitting into existing factory automation architectures.
Fuzzy MCP Gateway should be designed to work alongside PLCs, safety-rated equipment, robot controllers, cell controllers, and operator procedures. MCP is the AI interface. Fuzzy Studio and Fuzzy RTC translate that intent into industrial robot workflows that can be coordinated with the rest of the cell.
The goal is to support MCP-compatible clients and custom AI applications. Examples may include developer tools, agent frameworks, and AI assistants that support MCP.
The first proposed demo is CAD to deburring: upload a CAD part, generate a Fuzzy Studio workcell, create a deburring trajectory, preview it, and request execution.
AI developers, physical AI teams, robotics startups, research groups, and industrial automation teams looking for agent-ready industrial robot workflows.